
Mechanism design
Parallel-jaw gripper
Exploring controlled gripping through jaw geometry, guided motion, and a compact drive system.
01 / THE IDEA
Start with the object.
A gripper begins with what it needs to hold. The object's shape, mass, and contact surfaces determine the useful opening and the kind of force the jaws need to apply.
This is an illustrative project preview. The model and drawings demonstrate the presentation format; they are not a completed or tested engineering project.
02 / THE DESIGN
A closer look.
03 / DEVELOPMENT
The questions behind the geometry.
The design study would compare transmission options, guide stiffness, finger geometry, and the surfaces that touch the object.
- Define the objects and gripping conditions.
- Compare motion and actuation options.
- Check force, travel, and interfaces.
- Develop the assembly, drawings, and a gripping test.
04 / OPTIONAL 3D VIEW
See how the parts relate.
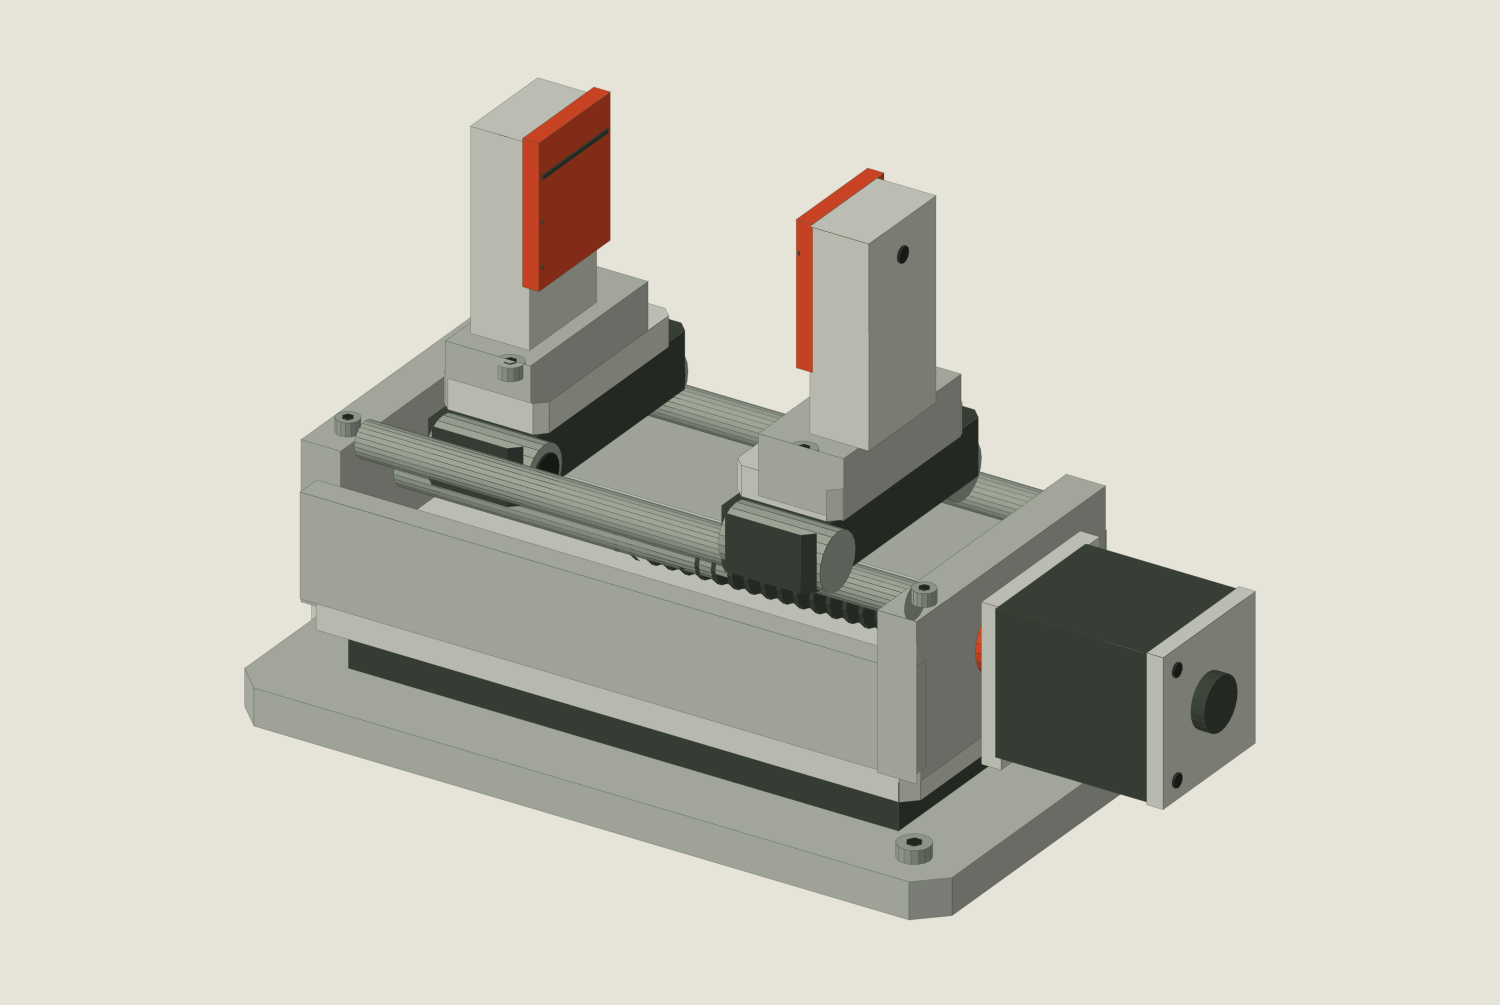
Explore the model in 3D
Drag to rotate · Arrow keys also work
Assembly view